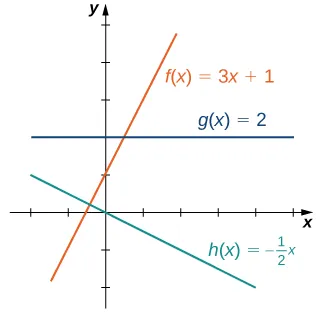We have studied the general characteristics of functions, so now let’s examine some specific classes of functions. We begin by reviewing the basic properties of linear and quadratic functions, and then generalize to include higher-degree polynomials. By combining root functions with polynomials, we can define general algebraic functions and distinguish them from the transcendental functions we examine later in this chapter. We finish the section with examples of piecewise-defined functions and take a look at how to sketch the graph of a function that has been shifted, stretched, or reflected from its initial form.
The easiest type of function to consider is a linear function. Linear functions have the form 𝑓(𝑥)=𝑎𝑥+𝑏,where 𝑎 and 𝑏 are constants. In Figure 1.2.1, we see examples of linear functions when 𝑎 is positive, negative, and zero. Note that if 𝑎>0, the graph of the line rises as 𝑥 increases. In other words, 𝑓(𝑥)=𝑎𝑥+𝑏 is increasing on (−∞, ∞). If 𝑎<0, the graph of the line falls as 𝑥 increases. In this case, 𝑓(𝑥)=𝑎𝑥+𝑏 is decreasing on (−∞, ∞). If 𝑎=0, the line is horizontal.
As suggested by Figure 1.2.1, the graph of any linear function is a line. One of the distinguishing features of a line is its slope. The slope is the change in 𝑦 for each unit change in 𝑥. The slope measures both the steepness and the direction of a line:
if the slope is positive, the line points upward when moving from left to right;
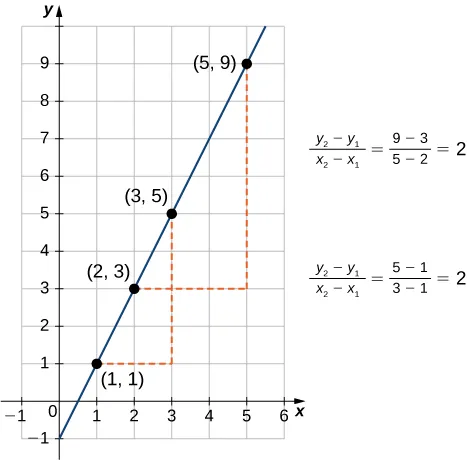
To calculate the slope of a line, we need to determine the ratio of the change in 𝑦 versus the change in 𝑥. To do so, we choose any two points \((𝑥_1,𝑦_1)\) and \((𝑥_2,𝑦_2)\) on the line and calculate
Figure1.2.2.For any linear function, the slope \((y_2−y_1)/(x_2−x_1)\) is independent of the choice of points \((x_1,y_1)\) and \((x_2,y_2)\) on the line.
Consider line 𝐿 passing through points \((x_1,y_1)\) and \((x_2,y_2)\text{.}\) Let \(Δ𝑦=y_2−y_1\) and \(Δ𝑥=x_2−x_1\) denote the changes in \(𝑦\) and \(𝑥\text{,}\) respectively. The slope of the line is
We now examine the relationship between slope and the formula for a linear function. Consider the linear function given by the formula 𝑓(𝑥)=𝑎𝑥+𝑏. As discussed earlier, we know the graph of a linear function is given by a line. We can use our definition of slope to calculate the slope of this line. As shown, we can determine the slope by calculating \((y_2−y_1)/(x_2−x_1)\) for any points \((x_1,y_1)\) and \((x_2,y_2)\) on the line. Evaluating the function 𝑓 at 𝑥=0, we see that (0,𝑏) is a point on this line. Evaluating this function at 𝑥=1, we see that (1,𝑎+𝑏) is also a point on this line. Therefore, the slope of this line is
We have shown that the coefficient 𝑎 is the slope of the line. We can conclude that the formula 𝑓(𝑥)=𝑎𝑥+𝑏 describes a line with slope 𝑎. Furthermore, because this line intersects the 𝑦-axis at the point (0,𝑏), we see that the 𝑦-intercept for this linear function is (0,𝑏). We conclude that the formula 𝑓(𝑥)=𝑎𝑥+𝑏 tells us the slope, 𝑎, and the 𝑦-intercept, (0,𝑏), for this line. Since we often use the symbol 𝑚 to denote the slope of a line, we can write
\begin{equation*}
𝑓(𝑥)=𝑚𝑥+𝑏
\end{equation*}
to denote the slope-intercept form of a linear function.
Sometimes it is convenient to express a linear function in different ways. For example, suppose the graph of a linear function passes through the point \((x_1,y_1)\) and the slope of the line is 𝑚. Since any other point \((𝑥,𝑓(𝑥))\) on the graph of 𝑓 must satisfy the equation
Since every nonvertical line is the graph of a linear function, the points on a nonvertical line can be described using the slope-intercept or point-slope equations. However, a vertical line does not represent the graph of a function and cannot be expressed in either of these forms. Instead, a vertical line is described by the equation 𝑥=𝑘 for some constant 𝑘.
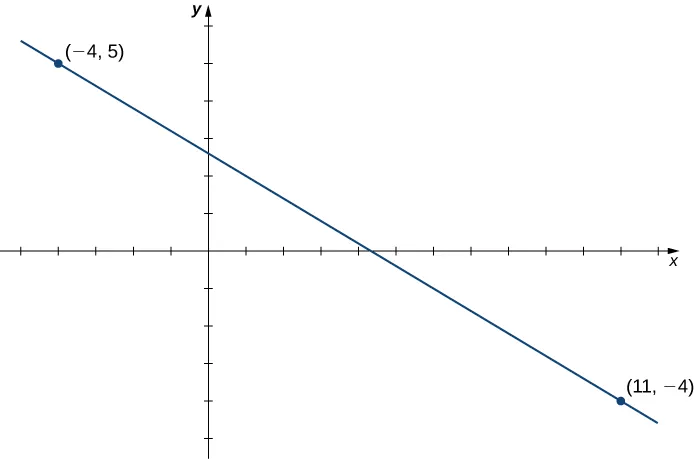
To find an equation for the linear function in point-slope form, use the slope 𝑚=−3/5 and choose any point on the line. If we choose the point (11,−4), we get the equation
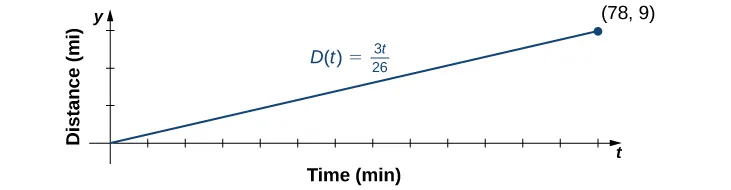
Jessica leaves her house at 5:50 a.m. and goes for a 9-mile run. She returns to her house at 7:08 a.m. Answer the following questions, assuming Jessica runs at a constant pace.
Describe the distance 𝐷 (in miles) Jessica runs as a linear function of her run time 𝑡 (in minutes).
At time 𝑡=0, Jessica is at her house, so 𝐷(0)=0. At time 𝑡=78 minutes, Jessica has finished running 9 mi, so 𝐷(78)=9. The slope of the linear function is
A linear function is a special type of a more general class of functions: polynomials. A polynomial function is any function that can be written in the form
for some integer 𝑛≥0 and constants \(𝑎_𝑛,𝑎_{𝑛−1},…,𝑎_0\text{,}\) where \(𝑎_𝑛≠0\text{.}\) In the case when 𝑛=0, we allow for \(𝑎_0=0\text{;}\) if \(𝑎_0=0\text{,}\) the function \(𝑓(𝑥)=0\) is called the zero function. The value 𝑛 is called the degree of the polynomial; the constant \(𝑎_𝑛\) is called the leading coefficient. A linear function of the form 𝑓(𝑥)=𝑚𝑥+𝑏 is a polynomial of degree 1 if 𝑚≠0 and degree 0 if 𝑚=0. A polynomial of degree 0 is also called a constant function. A polynomial function of degree 2 is called a quadratic function. In particular, a quadratic function has the form \(𝑓(𝑥)=𝑎x^2+𝑏𝑥+𝑐\text{,}\) where 𝑎≠0. A polynomial function of degree 3 is called a cubic function.
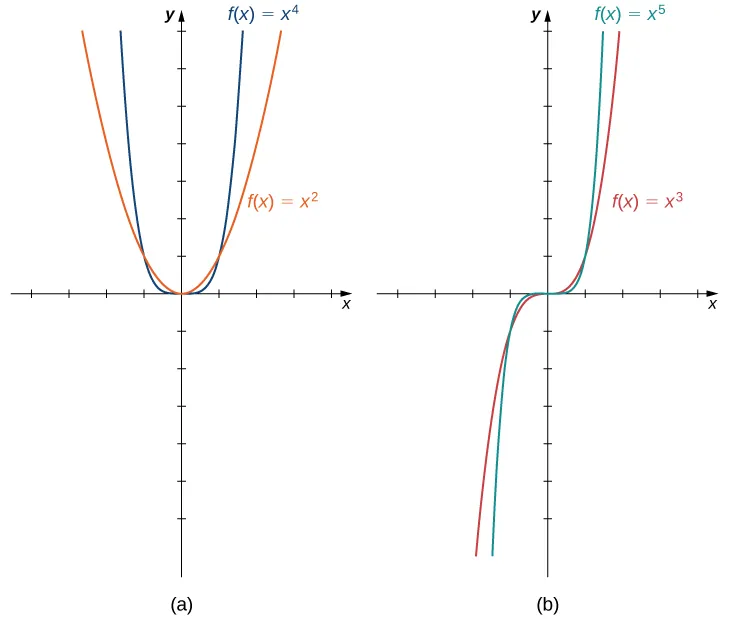
Some polynomial functions are power functions. A power function is any function of the form \(𝑓(𝑥)=𝑎𝑥^𝑏\text{,}\) where 𝑎 and 𝑏 are any real numbers. The exponent in a power function can be any real number, but here we consider the case when the exponent is a positive integer. (We consider other cases later.) If the exponent is a positive integer, then \(𝑓(𝑥)=𝑎𝑥^𝑛\) is a polynomial. If 𝑛 is even, then \(𝑓(𝑥)=𝑎𝑥^𝑛\) is an even function because \(𝑓(−𝑥)=𝑎(−𝑥)𝑛=𝑎𝑥^𝑛\) if 𝑛 is even. If 𝑛 is odd, then \(𝑓(𝑥)=𝑎𝑥^𝑛\) is an odd function because \(𝑓(−𝑥)=𝑎(−𝑥)𝑛=−𝑎𝑥^𝑛\) if 𝑛 is odd (Figure 1.2.9).
To determine the behavior of a function 𝑓 as the inputs approach infinity, we look at the values 𝑓(𝑥) as the inputs, 𝑥, become larger. For some functions, the values of 𝑓(𝑥) approach a finite number. For example, for the function \(𝑓(𝑥)=2+1/𝑥\text{,}\) the values 1/𝑥 become closer and closer to zero for all values of 𝑥 as they get larger and larger. For this function, we say “𝑓(𝑥) approaches two as 𝑥 goes to infinity,” and we write \(𝑓(𝑥)\to2\) as \(𝑥\to∞\text{.}\) The line 𝑦=2 is a horizontal asymptote for the function \(𝑓(𝑥)=2+1/𝑥\) because the graph of the function gets closer to the line as 𝑥 gets larger.
For other functions, the values 𝑓(𝑥) may not approach a finite number but instead may become larger for all values of 𝑥 as they get larger. In that case, we say “𝑓(𝑥) approaches infinity as 𝑥 approaches infinity,” and we write \(𝑓(𝑥)\to∞\) as \(𝑥\to∞\text{.}\) For example, for the function \(𝑓(𝑥)=3x^2\text{,}\) the outputs 𝑓(𝑥) become larger as the inputs 𝑥 get larger. We can conclude that the function \(𝑓(𝑥)=3x^2\) approaches infinity as 𝑥 approaches infinity, and we write \(3x^2\to∞\) as \(𝑥\to∞\text{.}\) The behavior as \(𝑥\to−∞\) and the meaning of \(𝑓(𝑥)\to−∞\) as \(𝑥\to∞\) or \(𝑥\to−∞\) can be defined similarly. We can describe what happens to the values of 𝑓(𝑥) as \(𝑥\to∞\) and as \(𝑥\to−∞\) as the end behavior of the function.
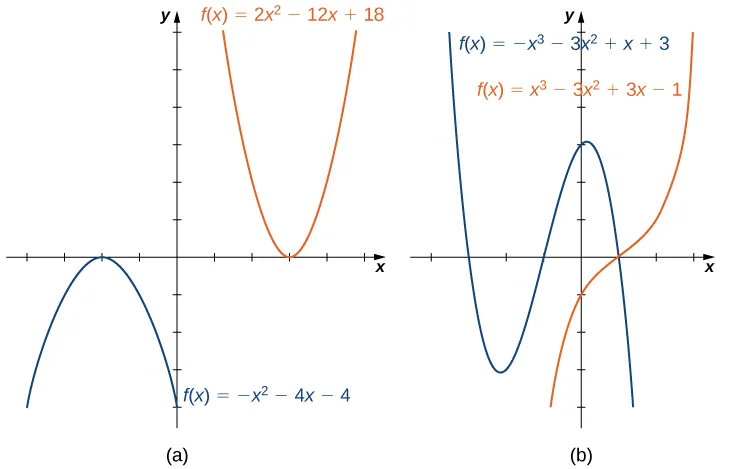
To understand the end behavior for polynomial functions, we can focus on quadratic and cubic functions. The behavior for higher-degree polynomials can be analyzed similarly. Consider a quadratic function \(𝑓(𝑥)=𝑎x^2+𝑏𝑥+𝑐\text{.}\) If 𝑎>0, the values \(𝑓(𝑥)\to∞\) as \(𝑥\to±∞\text{.}\) If 𝑎<0, the values \(𝑓(𝑥)\to−∞\) as \(𝑥\to±∞\text{.}\) Since the graph of a quadratic function is a parabola, the parabola opens upward if 𝑎>0; the parabola opens downward if 𝑎<0. (See Figure 1.2.10(a).)
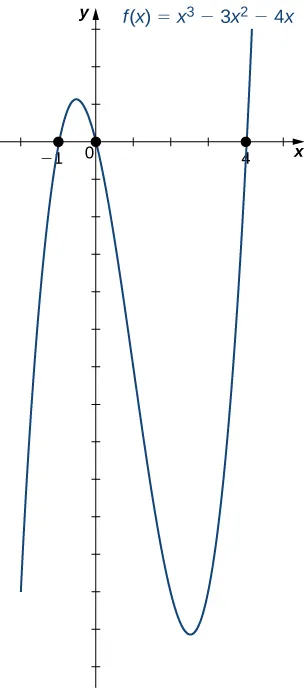
Now consider a cubic function \(𝑓(𝑥)=𝑎𝑥^3+𝑏𝑥^2+𝑐𝑥+𝑑\text{.}\) If 𝑎>0, then \(𝑓(𝑥)\to∞\) as \(𝑥\to∞\) and \(𝑓(𝑥)\to−∞\) as \(𝑥\to−∞\text{.}\) If 𝑎<0, then \(𝑓(𝑥)\to−∞\) as \(𝑥\to∞\) and \(𝑓(𝑥)\to∞\) as \(𝑥\to−∞\text{.}\) As we can see from both of these graphs, the leading term of the polynomial determines the end behavior. (See Figure 1.2.10(b).)
Figure1.2.10.(a) For a quadratic function, if the leading coefficient 𝑎>0, the parabola opens upward. If 𝑎<0, the parabola opens downward. (b) For a cubic function 𝑓, if the leading coefficient 𝑎>0, the values \(𝑓(𝑥)\to∞\) as \(𝑥\to∞\) and the values \(𝑓(𝑥)\to−∞\) as \(𝑥\to−∞\text{.}\) If the leading coefficient 𝑎<0, the opposite is true.
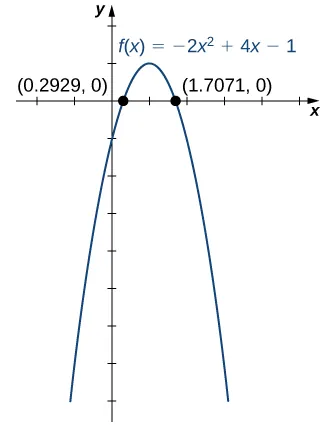
Another characteristic of the graph of a polynomial function is where it intersects the 𝑥-axis. To determine where a function 𝑓 intersects the 𝑥-axis, we need to solve the equation 𝑓(𝑥)=0 for x. In the case of the linear function 𝑓(𝑥)=𝑚𝑥+𝑏, the 𝑥-intercept is given by solving the equation 𝑚𝑥+𝑏=0. In this case, we see that the 𝑥-intercept is given by (−𝑏/𝑚,0). In the case of a quadratic function, finding the 𝑥-intercept(s) requires finding the zeros of a quadratic equation: \(𝑎x^2+𝑏𝑥+𝑐=0\text{.}\) In some cases, it is easy to factor the polynomial \(𝑎𝑥^2+𝑏𝑥+𝑐\) to find the zeros. If not, we make use of the quadratic formula.
Definition1.2.11.The Quadratic Formula.
Consider the quadratic equation \(𝑎𝑥^2+𝑏𝑥+𝑐=0\text{,}\) where 𝑎≠0. The solutions of this equation are given by the quadratic formula
If the discriminant \(𝑏^2−4𝑎𝑐>0\text{,}\) this formula tells us there are two real numbers that satisfy the quadratic equation. If \(𝑏^2−4𝑎𝑐=0\text{,}\) this formula tells us there is only one solution, and it is a real number. If \(𝑏^2−4𝑎𝑐<0\text{,}\) no real numbers satisfy the quadratic equation.
In the case of higher-degree polynomials, it may be more complicated to determine where the graph intersects the 𝑥-axis. In some instances, it is possible to find the 𝑥-intercepts by factoring the polynomial to find its zeros. In other cases, it is impossible to calculate the exact values of the 𝑥-intercepts. However, as we see later in the text, in cases such as this, we can use analytical tools to approximate (to a very high degree) where the 𝑥-intercepts are located. Here we focus on the graphs of polynomials for which we can calculate their zeros explicitly.
A large variety of real-world situations can be described using mathematical models. A mathematical model is a method of simulating real-life situations with mathematical equations. Physicists, engineers, economists, and other researchers develop models by combining observation with quantitative data to develop equations, functions, graphs, and other mathematical tools to describe the behavior of various systems accurately. Models are useful because they help predict future outcomes. Examples of mathematical models include the study of population dynamics, investigations of weather patterns, and predictions of product sales.
As an example, let’s consider a mathematical model that a company could use to describe its revenue for the sale of a particular item. The amount of revenue 𝑅 a company receives for the sale of 𝑛 items sold at a price of 𝑝 dollars per item is described by the equation 𝑅=𝑝·𝑛. The company is interested in how the sales change as the price of the item changes. Suppose the data in Table 1.2.15 show the number of units a company sells as a function of the price per item.
Table1.2.15.Number of Units Sold 𝑛 (in Thousands) as a Function of Price per Unit 𝑝 (in Dollars).
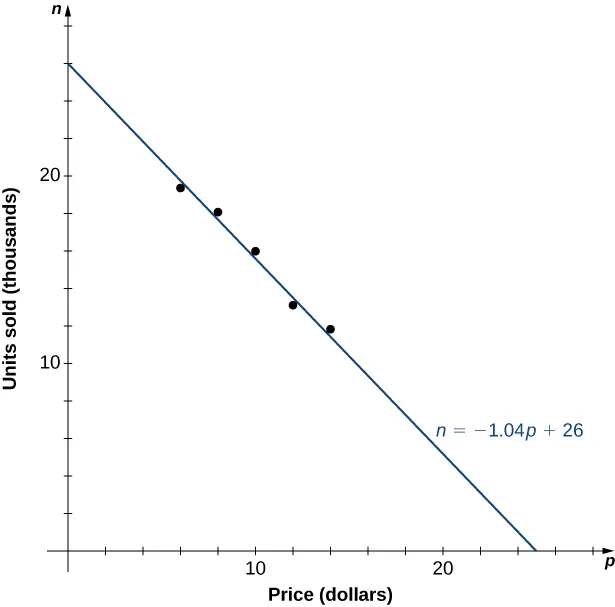
In Figure 1.2.13, we see the graph the number of units sold (in thousands) as a function of price (in dollars). We note from the shape of the graph that the number of units sold is likely a linear function of price per item, and the data can be closely approximated by the linear function 𝑛=−1.04𝑝+26 for 0≤𝑝≤25, where 𝑛 predicts the number of units sold in thousands. Using this linear function, the revenue (in thousands of dollars) can be estimated by the quadratic function
\begin{equation*}
𝑅(𝑝)=𝑝·(−1.04𝑝+26)=−1.04𝑝^2+26𝑝\text{ for }0≤𝑝≤25.
\end{equation*}
In Example 1.2.17, we use this quadratic function to predict the amount of revenue the company receives depending on the price the company charges per item. Note that we cannot conclude definitively the actual number of units sold for values of 𝑝, for which no data are collected. However, given the other data values and the graph shown, it seems reasonable that the number of units sold (in thousands) if the price charged is 𝑝 dollars may be close to the values predicted by the linear function
Figure1.2.16.The data collected for the number of items sold as a function of price is roughly linear. We use the linear function 𝑛=−1.04𝑝+26 to estimate this function.
A company is interested in predicting the amount of revenue it will receive depending on the price it charges for a particular item. Using the data from Table 1.6, the company arrives at the following quadratic function to model revenue 𝑅 (in thousands of dollars) as a function of price per item 𝑝:
\begin{equation*}
𝑅(𝑝)=𝑝·(−1.04𝑝+26)=−1.04𝑝2+26𝑝\text{ for }0≤𝑝≤25.
\end{equation*}
Predict the revenue if the company sells the item at a price of 𝑝=$5 and 𝑝=$17.
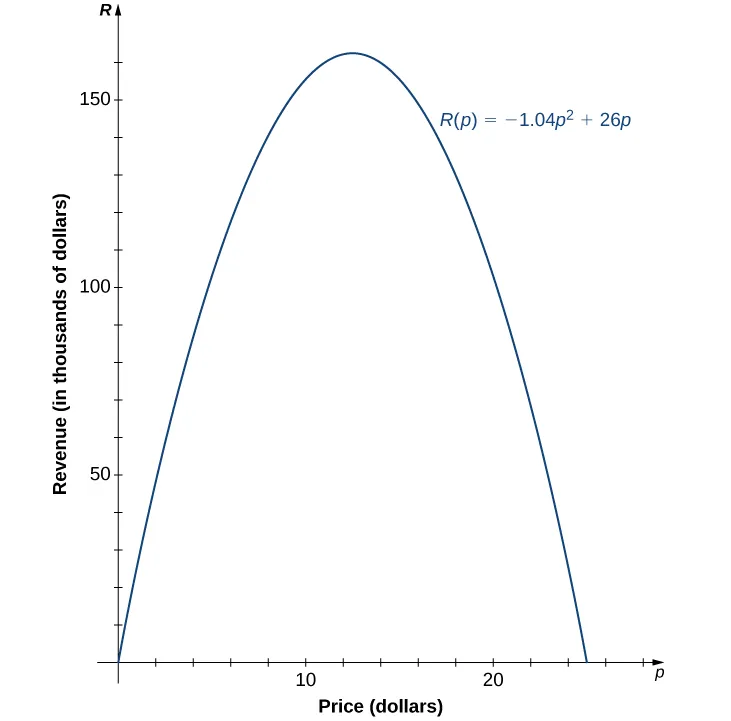
The zeros of this function can be found by solving the equation \(−1.04𝑝^2+26𝑝=0\text{.}\) When we factor the quadratic expression, we get \(p(−1.04𝑝+26)=0\text{.}\) The solutions to this equation are given by 𝑝=0,25. For these values of 𝑝, the revenue is zero. When 𝑝=$0, the revenue is zero because the company is giving away its merchandise for free. When 𝑝=$25, the revenue is zero because the price is too high, and no one will buy any items.
Knowing the fact that the function is quadratic, we also know the graph is a parabola. Since the leading coefficient is negative, the parabola opens downward. One property of parabolas is that they are symmetric about the axis, so since the zeros are at 𝑝=0 and 𝑝=25, the parabola must be symmetric about the line halfway between them, or 𝑝=12.5.
The function is a parabola with zeros at 𝑝=0 and 𝑝=25, and it is symmetric about the line 𝑝=12.5, so the maximum revenue occurs at a price of 𝑝=$12.50 per item. At that price, the revenue is \(𝑅(𝑝)=−1.04(12.5)2+26(12.5)=$162,500.\)
By allowing for quotients and fractional powers in polynomial functions, we create a larger class of functions. An algebraic function is one that involves addition, subtraction, multiplication, division, rational powers, and roots. Two types of algebraic functions are rational functions and root functions.
Just as rational numbers are quotients of integers, rational functions are quotients of polynomials. In particular, a rational function is any function of the form 𝑓(𝑥)=𝑝(𝑥)/𝑞(𝑥), where 𝑝(𝑥) and 𝑞(𝑥) are polynomials. For example,
\begin{equation*}
𝑓(𝑥)=\frac{3𝑥−1}{5𝑥+2}\text{ and }𝑔(𝑥)=\frac{4}{𝑥^2+1}
\end{equation*}
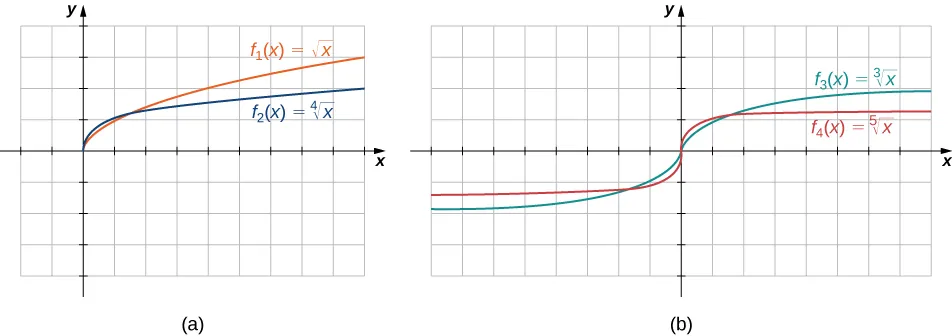
are rational functions. A root function is a power function of the form \(𝑓(𝑥)=x^{1/𝑛}\text{,}\) where 𝑛 is a positive integer greater than one. For example, \(𝑓(𝑥)=x^{1/2}=\sqrt{𝑥}\) is the square-root function and \(𝑔(𝑥)=x^{1/3}=\sqrt[3]{𝑥}\) is the cube-root function. By allowing for compositions of root functions and rational functions, we can create other algebraic functions. For example, \(𝑓(𝑥)=\sqrt{4−x_2}\) is an algebraic function. The root functions \(𝑓(𝑥)=𝑥^{1/𝑛}\) have defining characteristics depending on whether 𝑛 is odd or even. For all even integers 𝑛≥2, the domain of \(𝑓(𝑥)=x^{1/𝑛}\) is the interval [0,∞). For all odd integers 𝑛≥1, the domain of \(𝑓(𝑥)=𝑥^{1/𝑛}\) is the set of all real numbers. Since \(𝑥^{1/𝑛}=−(−𝑥)^{1/𝑛}\) for odd integers 𝑛,\(𝑓(𝑥)=𝑥^{1/𝑛}\) is an odd function if 𝑛 is odd. See the graphs of root functions for different values of 𝑛 in Figure 1.2.19.
Figure1.2.19.(a) If 𝑛 is even, the domain of \(𝑓(𝑥)=\sqrt[𝑛]{𝑥}\) is [0,∞). (b) If 𝑛 is odd, the domain of \(𝑓(𝑥)=\sqrt[𝑛]{𝑥}\) is (−∞,∞) and the function \(𝑓(𝑥)=\sqrt[𝑛]{𝑥}\) is an odd function.
You need to determine the values of 𝑥 for which the denominator is zero. Since 3𝑥2+4≥4 for all real numbers 𝑥, the denominator is never zero. Therefore, the domain is (−∞,∞).
Since the square root of a negative number is not a real number, the domain is the set of values 𝑥 for which 4−3𝑥≥0. Therefore, the domain is {𝑥|𝑥≤4/3}.
Thus far, we have discussed algebraic functions. Some functions, however, cannot be described by basic algebraic operations. These functions are known as transcendental functions because they are said to “transcend,” or go beyond, algebra. The most common transcendental functions are trigonometric, exponential, and logarithmic functions. A trigonometric function relates the ratios of two sides of a right triangle. They are \(\sin 𝑥,\cos 𝑥,\tan 𝑥,\cot 𝑥,\sec 𝑥,\)and \(\csc 𝑥\text{.}\) (We discuss trigonometric functions later in the chapter.) An exponential function is a function of the form \(𝑓(𝑥)=𝑏^𝑥\text{,}\) where the base 𝑏>0,𝑏≠1. A logarithmic function is a function of the form \(𝑓(𝑥)=log_𝑏(𝑥)\) for some constant 𝑏>0,𝑏≠1, where \(log_𝑏(𝑥)=𝑦\) if and only if \(𝑏^𝑦=𝑥\text{.}\) (We also discuss exponential and logarithmic functions later in the chapter.)
Example1.2.21.Classifying Algebraic and Transcendental Functions.
Classify each of the following functions, a. through c., as algebraic or transcendental.
This function cannot be written as a formula that involves only basic algebraic operations, so it is transcendental. (Note that algebraic functions can only have powers that are rational numbers.)
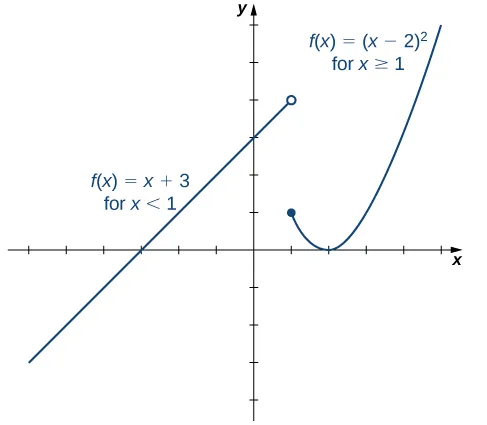
Sometimes a function is defined by different formulas on different parts of its domain. A function with this property is known as a piecewise-defined function. The absolute value function is an example of a piecewise-defined function because the formula changes with the sign of 𝑥:
Other piecewise-defined functions may be represented by completely different formulas, depending on the part of the domain in which a point falls. To graph a piecewise-defined function, we graph each part of the function in its respective domain, on the same coordinate system. If the formula for a function is different for 𝑥<𝑎 and 𝑥>𝑎, we need to pay special attention to what happens at 𝑥=𝑎 when we graph the function. Sometimes the graph needs to include an open or closed circle to indicate the value of the function at 𝑥=𝑎.
Example1.2.24.Parking Fees Described by a Piecewise-Defined Function.
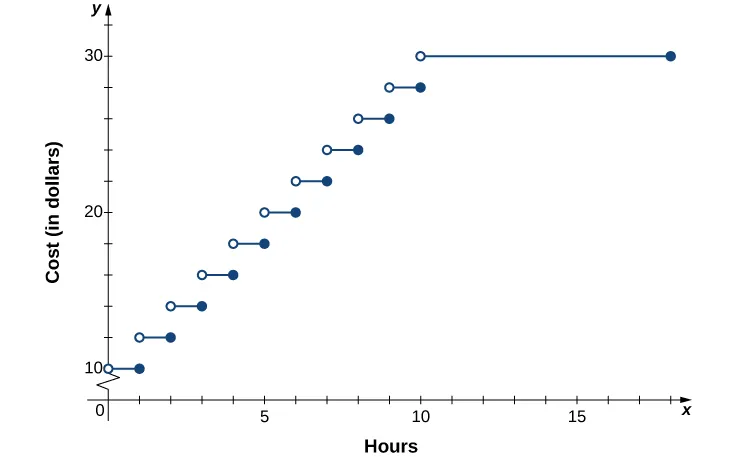
In a big city, drivers are charged variable rates for parking in a parking garage. They are charged $10 for the first hour or any part of the first hour and an additional $2 for each hour or part thereof up to a maximum of $30 for the day. The parking garage is open from 6 a.m. to 12 midnight.
Write a piecewise-defined function that describes the cost 𝐶 to park in the parking garage as a function of hours parked 𝑥.
Since the parking garage is open 18 hours each day, the domain for this function is {𝑥|0<𝑥≤18}. The cost to park a car at this parking garage can be described piecewise by the function
We have seen several cases in which we have added, subtracted, or multiplied constants to form variations of simple functions. In the previous example, for instance, we subtracted 2 from the argument of the function \(𝑦=𝑥^2\) to get the function \(𝑓(𝑥)=(𝑥−2)^2\text{.}\) This subtraction represents a shift of the function \(𝑦=𝑥^2\) two units to the right. A shift, horizontally or vertically, is a type of transformation of a function. Other transformations include horizontal and vertical scalings, and reflections about the axes.
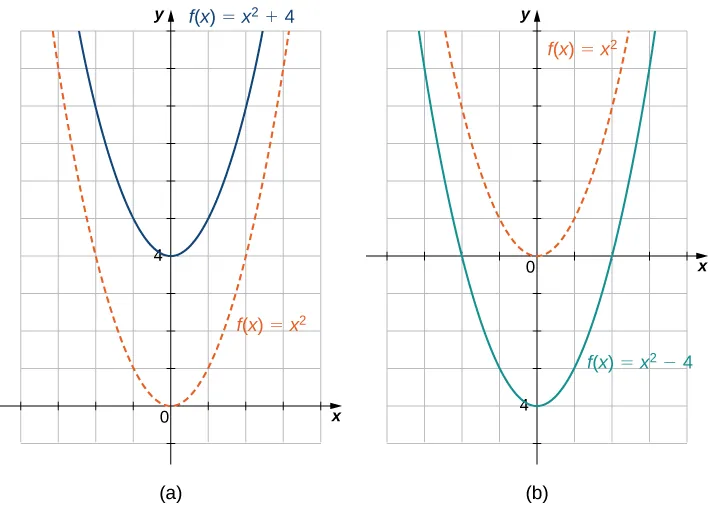
A vertical shift of a function occurs if we add or subtract the same constant to each output 𝑦. For 𝑐>0, the graph of 𝑓(𝑥)+𝑐 is a shift of the graph of 𝑓(𝑥) up 𝑐 units, whereas the graph of 𝑓(𝑥)−𝑐 is a shift of the graph of 𝑓(𝑥) down 𝑐 units. For example, the graph of the function \(𝑓(𝑥)=x^2+4\) is the graph of \(𝑦=x^2\) shifted up 4 units; the graph of the function \(𝑓(𝑥)=x^2−4\) is the graph of \(𝑦=x^2\) shifted down 4 units (Figure 1.2.26).
Figure1.2.26.(a) For 𝑐>0, the graph of 𝑦=𝑓(𝑥)+𝑐 is a vertical shift up 𝑐 units of the graph of 𝑦=𝑓(𝑥). (b) For 𝑐>0, the graph of 𝑦=𝑓(𝑥)−𝑐 is a vertical shift down 𝑐 units of the graph of 𝑦=𝑓(𝑥).
A horizontal shift of a function occurs if we add or subtract the same constant to each input 𝑥. For 𝑐>0, the graph of 𝑓(𝑥+𝑐) is a shift of the graph of 𝑓(𝑥) to the left 𝑐 units; the graph of 𝑓(𝑥−𝑐) is a shift of the graph of 𝑓(𝑥) to the right 𝑐 units. Why does the graph shift left when adding a constant and shift right when subtracting a constant? To answer this question, let’s look at an example.
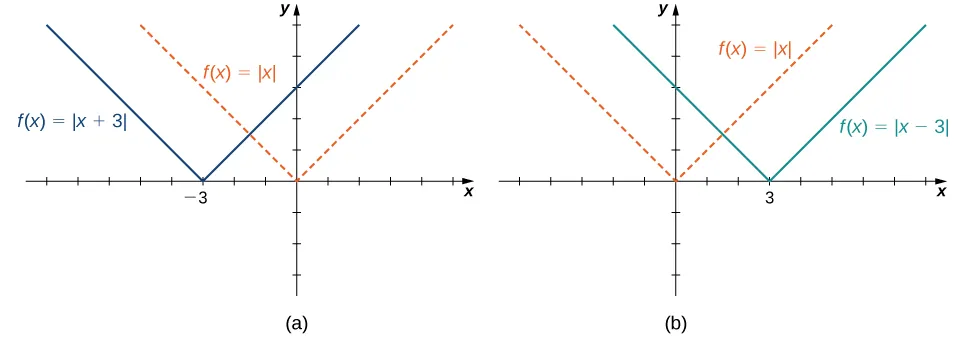
Consider the function \(𝑓(𝑥)=|𝑥+3|\) and evaluate this function at 𝑥−3. Since \(𝑓(𝑥−3)=|𝑥|\) and \(𝑥−3<𝑥\text{,}\) the graph of 𝑓(𝑥)=|𝑥+3| is the graph of 𝑦=|𝑥| shifted left 3 units. Similarly, the graph of 𝑓(𝑥)=|𝑥−3| is the graph of 𝑦=|𝑥| shifted right 3 units (Figure 1.2.27).
Figure1.2.27.(a) For 𝑐>0, the graph of 𝑦=𝑓(𝑥+𝑐) is a horizontal shift left 𝑐 units of the graph of 𝑦=𝑓(𝑥). (b) For 𝑐>0, the graph of 𝑦=𝑓(𝑥−𝑐) is a horizontal shift right 𝑐 units of the graph of 𝑦=𝑓(𝑥).
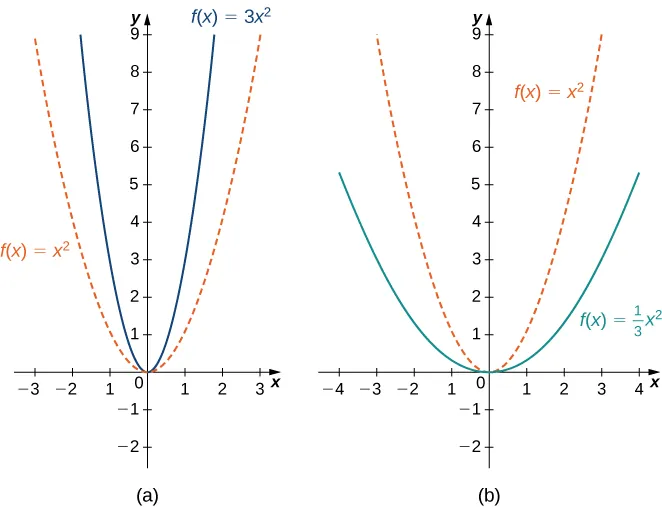
A vertical scaling of a graph occurs if we multiply all outputs 𝑦 of a function by the same positive constant. For 𝑐>0, the graph of the function 𝑐𝑓(𝑥) is the graph of 𝑓(𝑥) scaled vertically by a factor of 𝑐. If 𝑐>1, the values of the outputs for the function 𝑐𝑓(𝑥) are larger than the values of the outputs for the function 𝑓(𝑥); therefore, the graph has been stretched vertically. If 0<𝑐<1, then the outputs of the function 𝑐𝑓(𝑥) are smaller, so the graph has been compressed. For example, the graph of the function \(𝑓(𝑥)=3𝑥^2\) is the graph of \(𝑦=𝑥^2\) stretched vertically by a factor of 3, whereas the graph of \(𝑓(𝑥)=𝑥^{2/3}\) is the graph of \(𝑦=𝑥^2\) compressed vertically by a factor of 3 (Figure 1.2.28).
Figure1.2.28.(a) If 𝑐>1, the graph of 𝑦=𝑐𝑓(𝑥) is a vertical stretch of the graph of 𝑦=𝑓(𝑥). (b) If 0<𝑐<1, the graph of 𝑦=𝑐𝑓(𝑥) is a vertical compression of the graph of 𝑦=𝑓(𝑥).
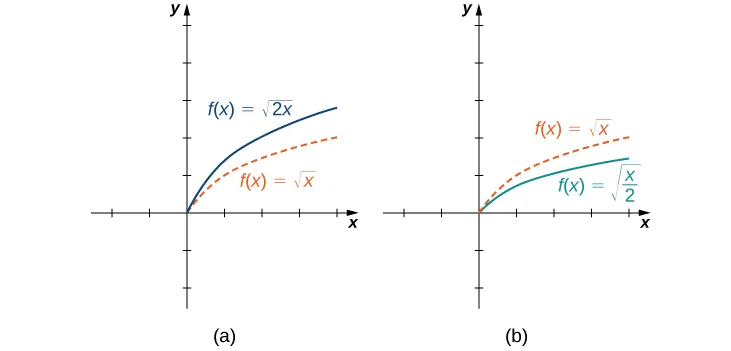
The horizontal scaling of a function occurs if we multiply the inputs 𝑥 by the same positive constant. For 𝑐>0, the graph of the function 𝑓(𝑐𝑥) is the graph of 𝑓(𝑥) scaled horizontally by a factor of 𝑐. If 𝑐>1, the graph of 𝑓(𝑐𝑥) is the graph of 𝑓(𝑥) compressed horizontally. If 0<𝑐<1, the graph of 𝑓(𝑐𝑥) is the graph of 𝑓(𝑥) stretched horizontally. For example, consider the function \(𝑓(𝑥)=\sqrt{2𝑥}\) and evaluate 𝑓 at 𝑥/2. Since \(𝑓(𝑥/2)=\sqrt{𝑥}\text{,}\) the graph of \(𝑓(𝑥)=\sqrt{2𝑥}\) is the graph of \(𝑦=\sqrt{𝑥}\) compressed horizontally. The graph of \(𝑦=\sqrt{𝑥/2}\) is a horizontal stretch of the graph of \(𝑦=\sqrt{𝑥}\) (Figure 1.2.29).
Figure1.2.29.(a) If 𝑐>1, the graph of 𝑦=𝑓(𝑐𝑥) is a horizontal compression of the graph of 𝑦=𝑓(𝑥). (b) If 0<𝑐<1, the graph of 𝑦=𝑓(𝑐𝑥) is a horizontal stretch of the graph of 𝑦=𝑓(𝑥).
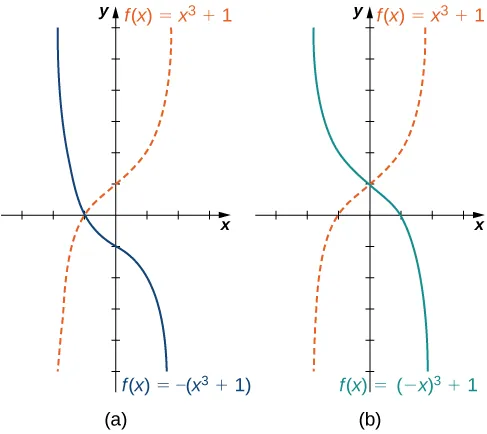
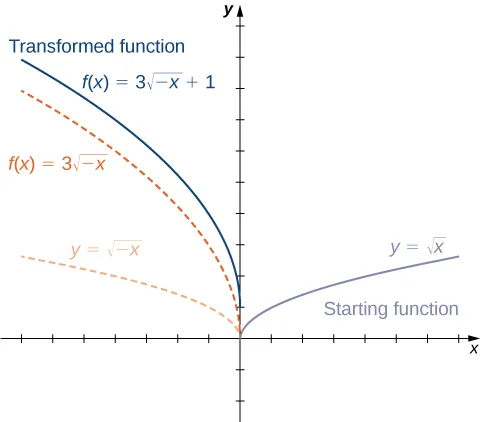
We have explored what happens to the graph of a function 𝑓 when we multiply 𝑓 by a constant 𝑐>0 to get a new function 𝑐𝑓(𝑥). We have also discussed what happens to the graph of a function 𝑓 when we multiply the independent variable 𝑥 by 𝑐>0 to get a new function 𝑓(𝑐𝑥). However, we have not addressed what happens to the graph of the function if the constant 𝑐 is negative. If we have a constant 𝑐<0, we can write c as a positive number multiplied by −1; but, what kind of transformation do we get when we multiply the function or its argument by −1? When we multiply all the outputs by −1, we get a reflection about the 𝑥-axis. When we multiply all inputs by −1, we get a reflection about the 𝑦-axis. For example, the graph of \(𝑓(𝑥)=−(𝑥^3+1)\) is the graph of \(𝑦=(𝑥^3+1)\) reflected about the 𝑥-axis. The graph of \(𝑓(𝑥)=(−𝑥)^3+1\) is the graph of \(𝑦=𝑥^3+1\) reflected about the 𝑦-axis (Figure 1.2.27).
Figure1.2.30.(a) The graph of 𝑦=−𝑓(𝑥) is the graph of 𝑦=𝑓(𝑥) reflected about the 𝑥-axis. (b) The graph of 𝑦=𝑓(−𝑥) is the graph of 𝑦=𝑓(𝑥) reflected about the 𝑦-axis.
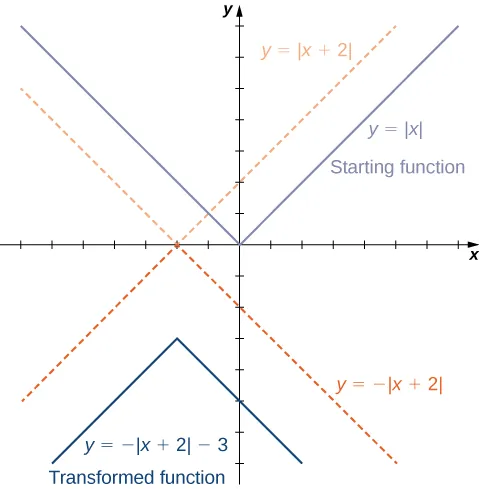
If the graph of a function consists of more than one transformation of another graph, it is important to transform the graph in the correct order. Given a function 𝑓(𝑥), the graph of the related function 𝑦=𝑐𝑓(𝑎(𝑥+𝑏))+𝑑 can be obtained from the graph of 𝑦=𝑓(𝑥) by performing the transformations in the following order.
Horizontal shift of the graph of 𝑦=𝑓(𝑥). If 𝑏>0, shift left. If 𝑏<0, shift right.
For the following exercises, for each pair of points, a. find the slope of the line passing through the points and b. indicate whether the line is increasing, decreasing, horizontal, or vertical.
For the following exercises, for each polynomial, a. find the degree; b. find the zeros, if any; c. find the 𝑦-intercept(s), if any; d. use the leading coefficient to determine the graph’s end behavior; and e. determine algebraically whether the polynomial is even, odd, or neither.